Multi-UAV Search Reconstruction and Scene Understanding for Post-Disaster Response
Project Team
Project Supervisor
Jinni ZHOU
Academic Supervisor
Jun MA, Yiding JI
Team members
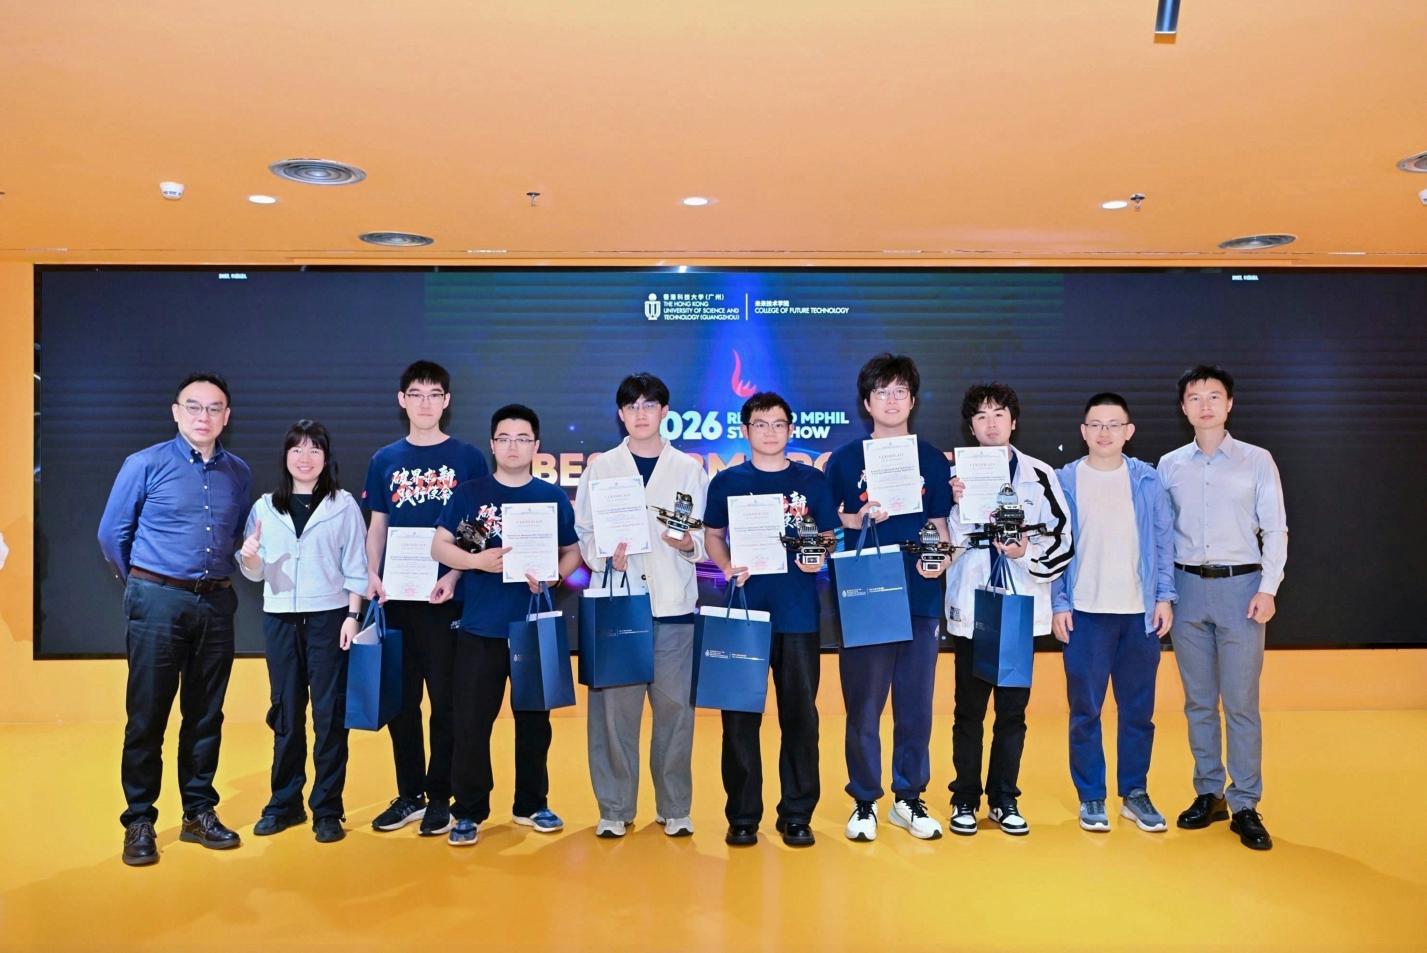
Hao GAO, Yinghong ZHANG, Zijun CHE, Mingjie ZHANG, Yuheng DU, Yunfei WANG
Project Overview
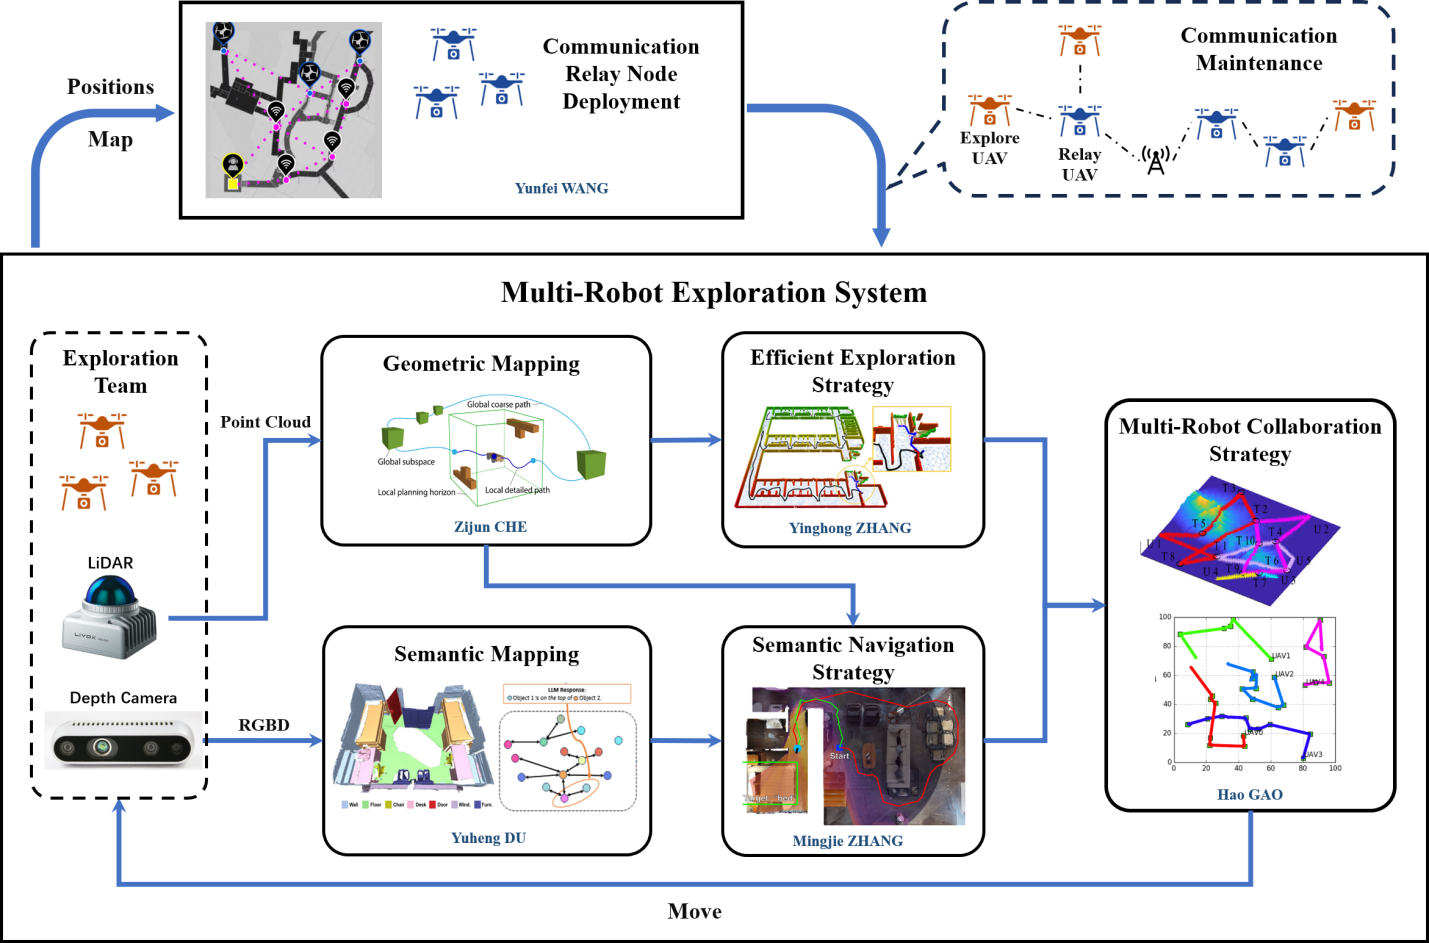
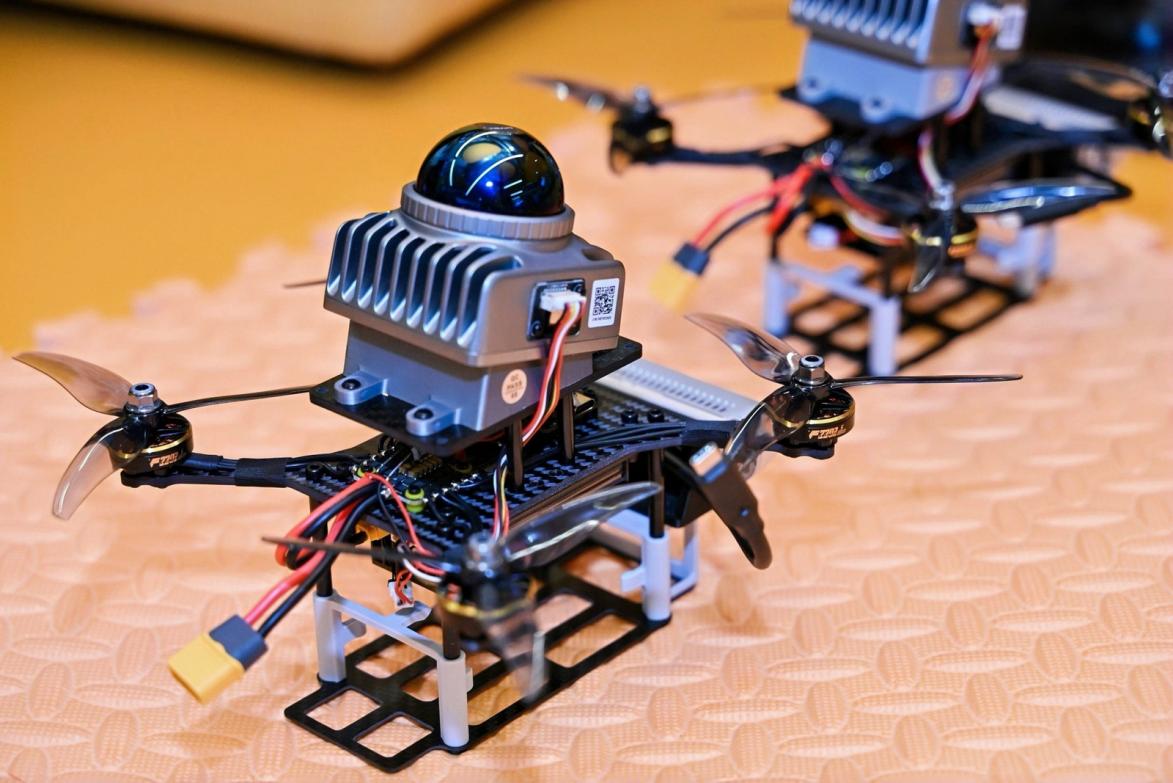
This project develops a dedicated multi-UAV system for post-disaster indoor and outdoor environments. It supports exploration, reconstruction, object search, and scene understanding, while improving the efficiency of disaster response.
Honor and achievements
Third Prize for Oral Presentation, The 5th Guangdong Postgraduate Academic Forum - Sub-forum on Intelligent Manufacturing and Robotics.
Che Z, Zhang Y, Liang S, et al. GUIDE: A Diffusion-Based Autonomous Robot Exploration Framework Using Global Graph Inference[J]. arXiv preprint arXiv:2509.19916, 2025.
Zhang M, Du Y, Wu C, et al. Apexnav: An adaptive exploration strategy for zero-shot object navigation with target-centric semantic fusion[J]. IEEE Robotics and Automation Letters, 2025.
Luo Y, Wang Y, Chen H, et al. Fermi: Flexible radio mapping with a hybrid propagation model and scalable autonomous data collection[J]. arXiv preprint arXiv:2504.14862, 2025.
Student Research Areas
Zijun CHE
Dynamic resolution mapping、UAV、Reinforcement Learning
Yinghong ZHANG
UAV、Reinforcement Learning、Path Planning
Mingjie ZHANG
UAV、Sematic Exploration、Sematic Navigation
Yuheng DU
UAV、Sematic Exploration、Sematic Navigation
Hao GAO
Multi-UAV、Task Allocation、Reinforcement Learning
Yunfei WANG
Multi-UAV、Communication Relay Node Deployment